Products » Survey Equipment » Innomar Medium 100
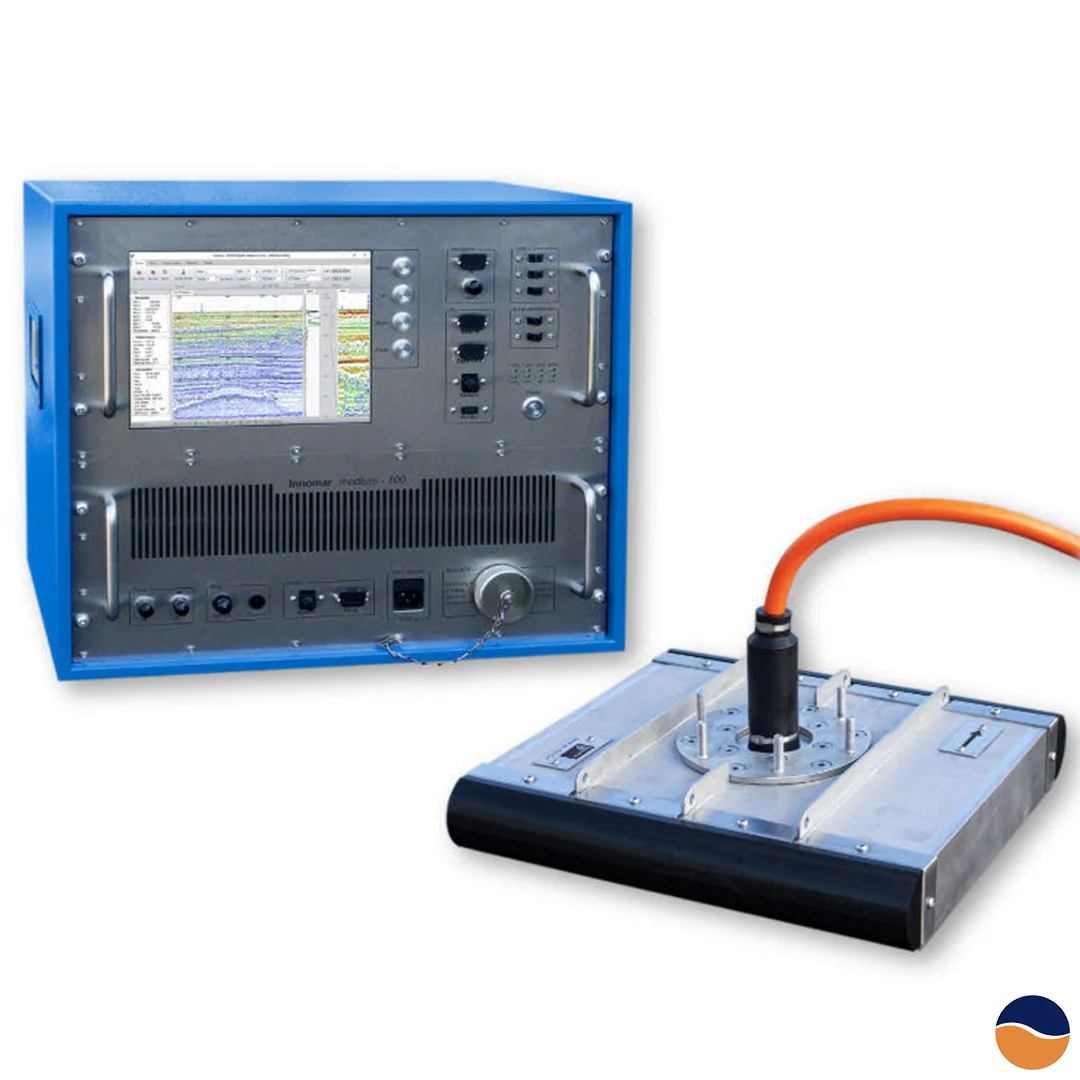
The Innomar Medium-100 is a parametric sub-bottom profiler designed for offshore surveys in water depths of up to 2,000 metres. Its transducer can be deployed over the side of a vessel or installed permanently in the hull, providing flexibility for temporary and dedicated survey configurations.
The Medium-100 combines sediment penetration of up to 70 metres with a sample resolution of approximately one centimetre. Its narrow acoustic beam produces a footprint of approximately 3.5% of the water depth, supporting detailed sub-bottom imaging in deep-water environments.
Selectable secondary frequencies from 4 to 15 kHz allow the system to be adapted to different survey objectives and sediment conditions. Ricker, CW and FM chirp pulses are available for further optimisation.
Heave and roll or pitch compensation stabilises the acoustic beam using data from an external motion sensor. This helps reduce the influence of vessel movement and improves the consistency of collected data.
The system supports ping rates of up to 40 Hz. Multi-ping mode helps maintain efficient data acquisition when operating in deeper water.
The Medium-100 records 24-bit full-waveform sub-bottom data in Innomar SES3 format. Data can be converted to SEG-Y using SESconvert and processed with compatible third-party seismic software.
Innomar also offers its dedicated ISE software for processing, visualising and interpreting data acquired with Innomar sub-bottom profilers.
The topside transceiver includes a Windows 10 or 11 computer with a 10-inch TFT display. Basic SESWIN functions can be controlled remotely through COM or UDP, while optional extended Ethernet control provides remote access to all survey settings.
| Specification | Value |
|---|---|
| Water-depth range | 2–2,000 m below the transducer |
| Sediment penetration | Up to 70 m, depending on sediment type and noise |
| Sample resolution | Approximately 1 cm |
| Range resolution | Up to 5 cm, depending on pulse settings |
| Transmit beam width at −3 dB | Approximately 2° × 2.5° at all frequencies |
| Acoustic footprint | Approximately 3.5% of water depth |
| Ping rate | Up to 40 Hz; multi-ping mode available |
| Motion compensation | Heave and roll or pitch using external sensor data |
| Primary frequency | Approximately 100 kHz; frequency band 85–115 kHz |
| Primary-frequency source level | Approximately 247 dB peak / 241 dB RMS re 1 µPa at 1 m |
| Selectable secondary frequencies | 4, 5, 6, 8, 10, 12 or 15 kHz |
| Secondary-frequency band | 2–22 kHz |
| Secondary-frequency pulse types | Ricker, CW and FM chirp |
| CW pulse width | User-selectable from 0.07 to 1.0 ms |
| Chirp pulse width | 3.5 ms |
| Data acquisition | Digital 24-bit at 96 kHz |
| Recorded data | SLF full waveform and PHF envelope |
| File formats | Innomar SES3; SEG-Y through SESconvert |
| External sensor interfaces | HRP motion, GNSS position and depth via RS-232 or UDP; BNC trigger |
| Bottom detection | Internal using PHF or SLF data, or external depth input |
| Depth accuracy | 2 cm at 100 kHz or 4 cm at 10 kHz, plus 0.02% of water depth |
| Remote control | KVM; basic COM or UDP control; NMEA; optional extended Ethernet control |
| Transducer installation | Over-the-side or hull-mounted |
| Transducer depth rating | Surface deployment |
| Power supply | 100–240 V AC |
| Power consumption | Approximately 250 W typical; 400 W maximum |
| Control and storage | Integrated Windows 10/11 PC with 10-inch TFT display |
| First/latest generation | 2004 / 2024 |
Enter your details to receive our latest news and events: