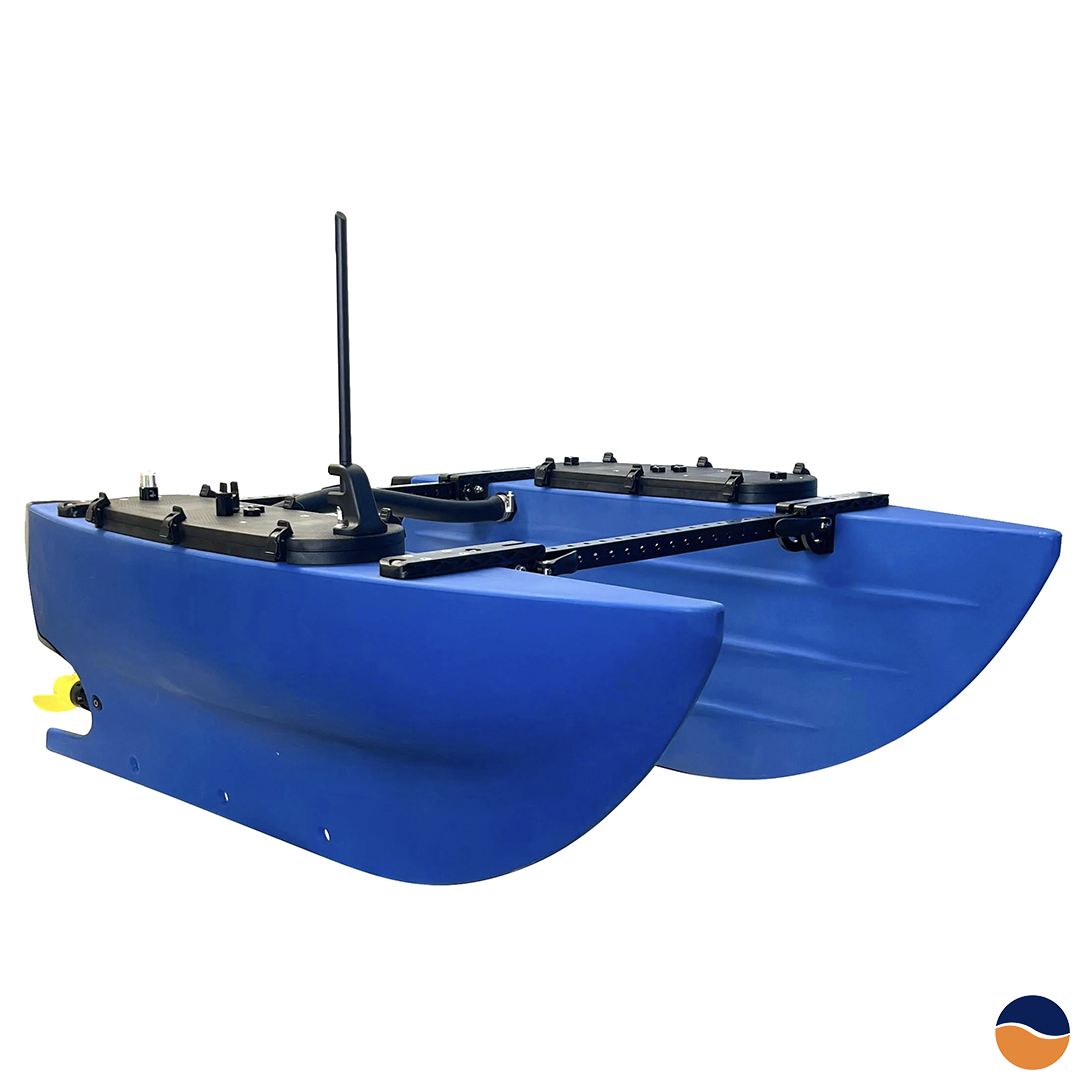
The BlueBoat is an affordable and highly configurable uncrewed surface vessel (USV) designed for hydrographic surveying, scientific research and robotic-system development.
Its weed-resistant hull, compact folding frame and open electronics architecture support reliable field operation and straightforward payload integration. Open-source BlueOS software provides a flexible foundation for autonomous missions, sonar integration and the development of custom robotic applications.
The BlueBoat’s control electronics, batteries and internal wiring are housed inside its twin hulls. This leaves the area between the hulls available for sonars, sensors and experimental equipment.
Flat inner hull walls create a low-wake sensor zone for hydrographic instruments. Mounting points on the crossmembers, brackets and hull underside allow users to install equipment such as:
Together, the batteries and installed payload may weigh up to 15 kg. Dry electronics areas in both hulls provide room for internal hardware, with access to payload power, inter-hull communication and openings for electrical penetrators or connectors.
BlueOS provides an open and expandable software environment for configuring the vessel and integrating additional systems. This makes the BlueBoat suitable for users who want to develop custom sensors, software and autonomous capabilities.
Its flexible electronics and software architecture allow the platform to grow with changing project requirements.
The deep hull shape is designed to push weeds and floating debris down and away from the vessel. Material that reaches the propulsion area is brushed aside by highly swept, weed-resistant propellers powered by two M200 motors.
This configuration helps reduce the risk of entanglement when operating in lakes, rivers and waterways containing vegetation or floating waste.
Every BlueBoat includes a Navigator Flight Controller, GPS and ArduRover control firmware. Standard autonomous functions include:
The vessel can also be operated manually using a compatible gamepad controller.
A long-range Wi-Fi radio connects the vessel to a BaseStation at distances of up to 250 metres when using the standard antennas. The BaseStation acts as a wireless access point for telemetry, vehicle control and mission management.
It includes an internal battery, USB-C charging and a wired network connection. Directional antennas can be used when a more focused wireless connection or extended operating range is required.
Multiple BlueBoats can connect through one BaseStation, supporting coordinated multi-vessel operations.
Battery capacity can be configured for different mission requirements. With the maximum supported number of batteries, the BlueBoat can operate continuously for more than 60 hours.
With one battery, operating time can exceed nine hours, with a travel range of more than 30 kilometres. Actual endurance and range depend on speed, payload, environmental conditions and battery configuration.
The folding hull and frame allow the BlueBoat to fit inside the luggage compartment of many passenger vehicles. Quick-release handles make it possible to change between folded and deployed configurations within seconds.
The vessel is supplied almost fully assembled and can be prepared for launch within a few minutes.
Fluorescent green and orange hull options provide strong visibility on the water. Additional colours are available for projects where identification, branding or appearance is important.
A medium- to high-performance laptop running Windows 10, macOS or Linux is recommended. Some Windows tablets, including Microsoft Surface devices, are also compatible. iOS and Android are not officially supported.
A compatible lithium-ion battery is required. A 14.8 V, 18 Ah battery is recommended for suitable operating time, although shipping restrictions may apply in some regions.
A compatible lithium-ion battery charger suitable for the selected battery is required.
A gamepad is optional for manual operation. Compatible controllers include the Xbox Wireless Controller and similar devices.
Enter your details to receive our latest news and events: