Products » Survey Equipment » Innomar Essential
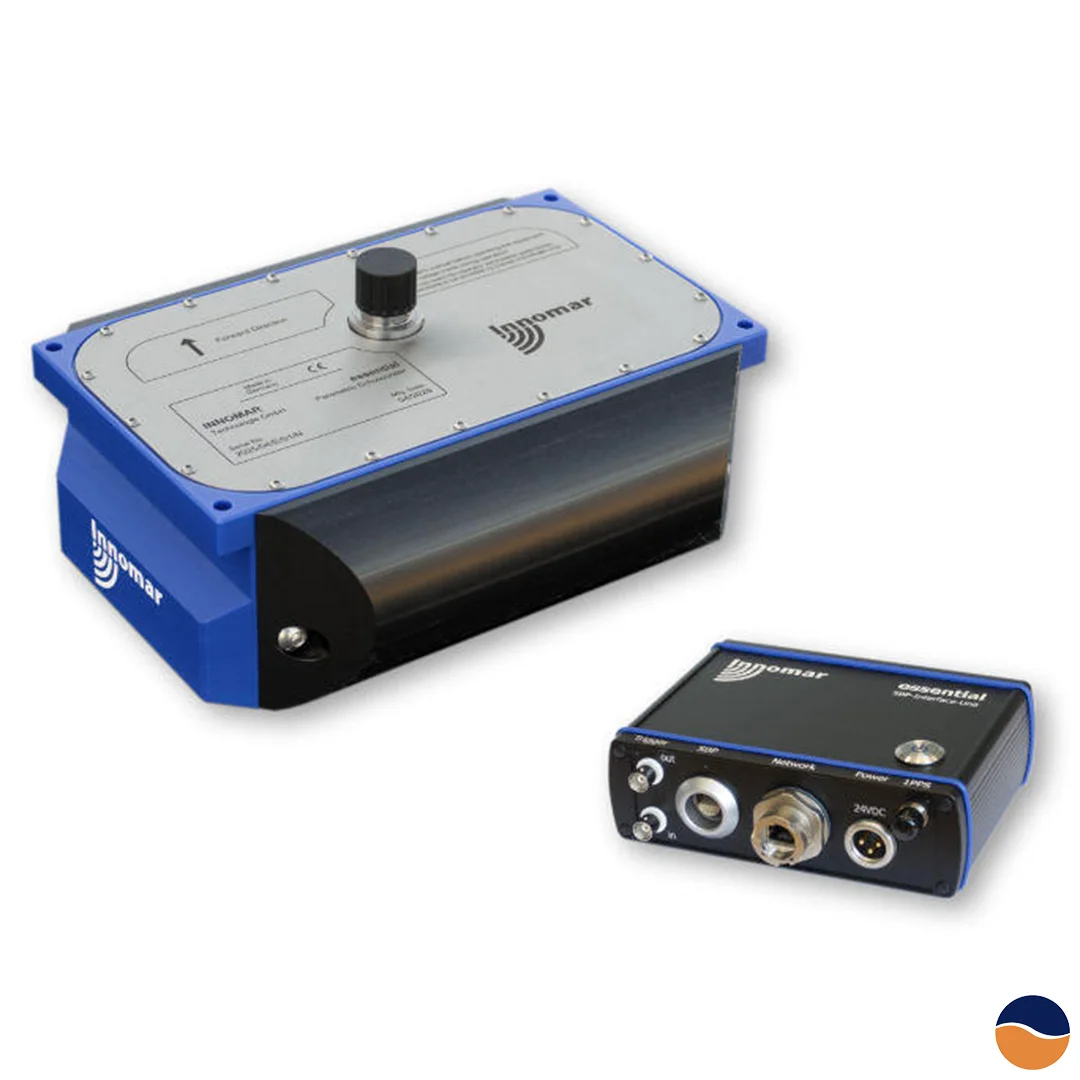
The Innomar Essential is a compact sub-bottom profiler designed for small survey vessels and uncrewed platforms, including USVs, ASVs and AUVs. Its high ping rate, broad frequency range and compact dimensions support detailed sub-bottom imaging with high resolution and effective sediment penetration.
All transceiver electronics are integrated into the transducer, simplifying installation and system integration. The supplied technical specifications state an operational depth rating of 60 metres and a survival depth of 100 metres.
The Innomar Essential operates with selectable secondary low frequencies between 6 and 15 kHz and a total frequency band of 3 to 22 kHz. Depending on sediment conditions, acoustic noise and pulse settings, the system can achieve sediment penetration of up to 30 metres and sample resolution of approximately one centimetre.
A ping rate of up to 25 Hz supports efficient data collection. Multi-ping operation helps maintain a high pulse rate when surveying in deeper water.
Integrated heave compensation reduces the effect of vertical platform movement on collected data. Optional electronic roll or pitch compensation of up to ±10° can further stabilise the acoustic beam.
Motion compensation requires data from a compatible external motion sensor, which is not included with the system.
The Innomar Essential is operated through SESWIN, Innomar’s Windows-based software for data acquisition, system control and remote survey integration.
The system records 24-bit full-waveform sub-bottom data in Innomar SES3 format. Data can be converted to SEG-Y using SESconvert for processing with compatible seismic software. Innomar’s dedicated ISE software provides an additional workflow for processing and interpreting Innomar SBP data.
| Specification | Value |
|---|---|
| Water-depth range | 0.5–200 m below the transducer |
| Sediment penetration | Up to 30 m, depending on sediment type and noise |
| Sample resolution | Approximately 1 cm |
| Range resolution | Up to 10 cm, depending on pulse settings |
| Transmit beam width at −3 dB | Approximately 4° across × 8° along at all frequencies |
| Motion compensation | Heave included; roll or pitch compensation up to ±10° optional |
| Ping rate | Up to 25 Hz |
| Primary frequency | Approximately 100 kHz; frequency band 85–115 kHz |
| Primary-frequency source level | Approximately 230 dB RMS / 236 dB peak re 1 µPa at 1 m |
| Selectable secondary frequencies | 6, 8, 10, 12 or 15 kHz |
| Secondary-frequency band | 3–22 kHz |
| Secondary-frequency pulse types | Ricker and CW |
| CW pulse width | User-selectable from 0.15 to 0.5 ms |
| Data acquisition | Digital 24-bit at approximately 100 kHz |
| Recorded data | SLF full waveform and PHF envelope |
| File formats | Innomar SES3; SEG-Y through SESconvert |
| External sensor interfaces | HRP motion, GNSS position and depth via RS-232 or UDP; BNC trigger |
| Bottom detection | Internal using PHF or SLF data, or external depth input |
| Depth accuracy | 2.5 cm at 100 kHz or 5 cm at 10 kHz, plus 0.08% of water depth |
| Remote control | SESWIN extended remote control |
| Transducer depth rating | 60 m operational; 100 m survival |
| Control and storage | External PC with Windows 10 or 11 |
| Product generation | 2026 |
Enter your details to receive our latest news and events: